Welcome aboard to the our video site for sailors. We are being constantly blasted by scammers and pirates, so registration is invite only
contact@sailorsahoy.com with "Invite". No spam, no newsletters. Just a free account
Korte broek Opprett

0
0
0
0
611

Paulo Cecconi explains the unique thrill of competitive yachting, where cutting-edge sail technology clashes with unpredictable sea conditions. Hear why this fierce competitor considers joining the North Sails team a lifelong dream realized. #PauloCecconi #Sailing #Yachting #NorthSails #SailTechnology #SailingLife #YachtRacing #EuroSailing --- As the undisputed global leader in sailmaking, North Sails pioneers performance-led design and advanced 3Di engineering across all wind-powered sports. From offshore yacht racing and one-design fleets to high-speed foiling and windsurfing, we build the fastest, most advanced sails and rigs on the water. Discover more at northsails.com. Subscribe for more great videos: https://www.youtube.com/@North_Sailssub_confirmation=1 ---
0
0
0
40

Attempting to Surf
0
0
0
1,187

A boater details his project: installing a new electric winch. Plus, the plan to donate the old winch for further use. Upgrades and generosity in action! #ElectricWinch #BoatProject #DIYBoating #MarineUpgrade

0
0
0
3

When old friends Rus and Fiona came to visit we were introduced to the 'I Like It Here' dance, a kind of tribal ritual that has to be carried out whenever one feels the need to express one's delight upon discovering a new place. This is a very important ceremony that must be executed with complete dedication. In this clip you'll see three experts carry out the 'I Like It Here' dance with great gusto. The lyrics were adapted to 'I Like It Up Here' to accomodate the location. [] www.followtheboat.com [] * tales from the high seas *
0
0
0
4,094
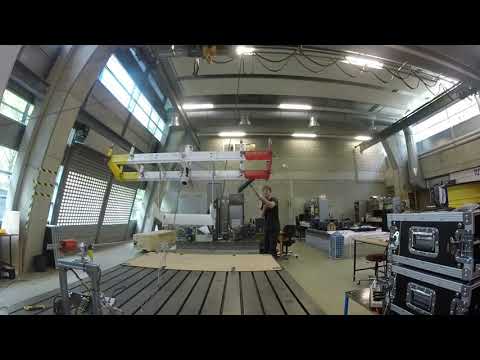
Test of the hover controller, in particular in yaw direction (multicopter frame, i.e. roll direction in airplane frame). The yaw is stabilized using the flaperons which are in the propeller wash. The flaperon deflections are visible when Chris pokes the kite with the broom. The controller quickly reacts and stabilizes smoothly the yaw angle back to zero. Note that differential propeller directions as used for small multicopter-drones do not offer nearly enough yaw moment for control authority of the kite's inertia or expected wind loads. In addition, such a control scheme greatly reduces the thrust for yaw stabilization. This is why this is not feasible for our system.
0
0
0
1,039
